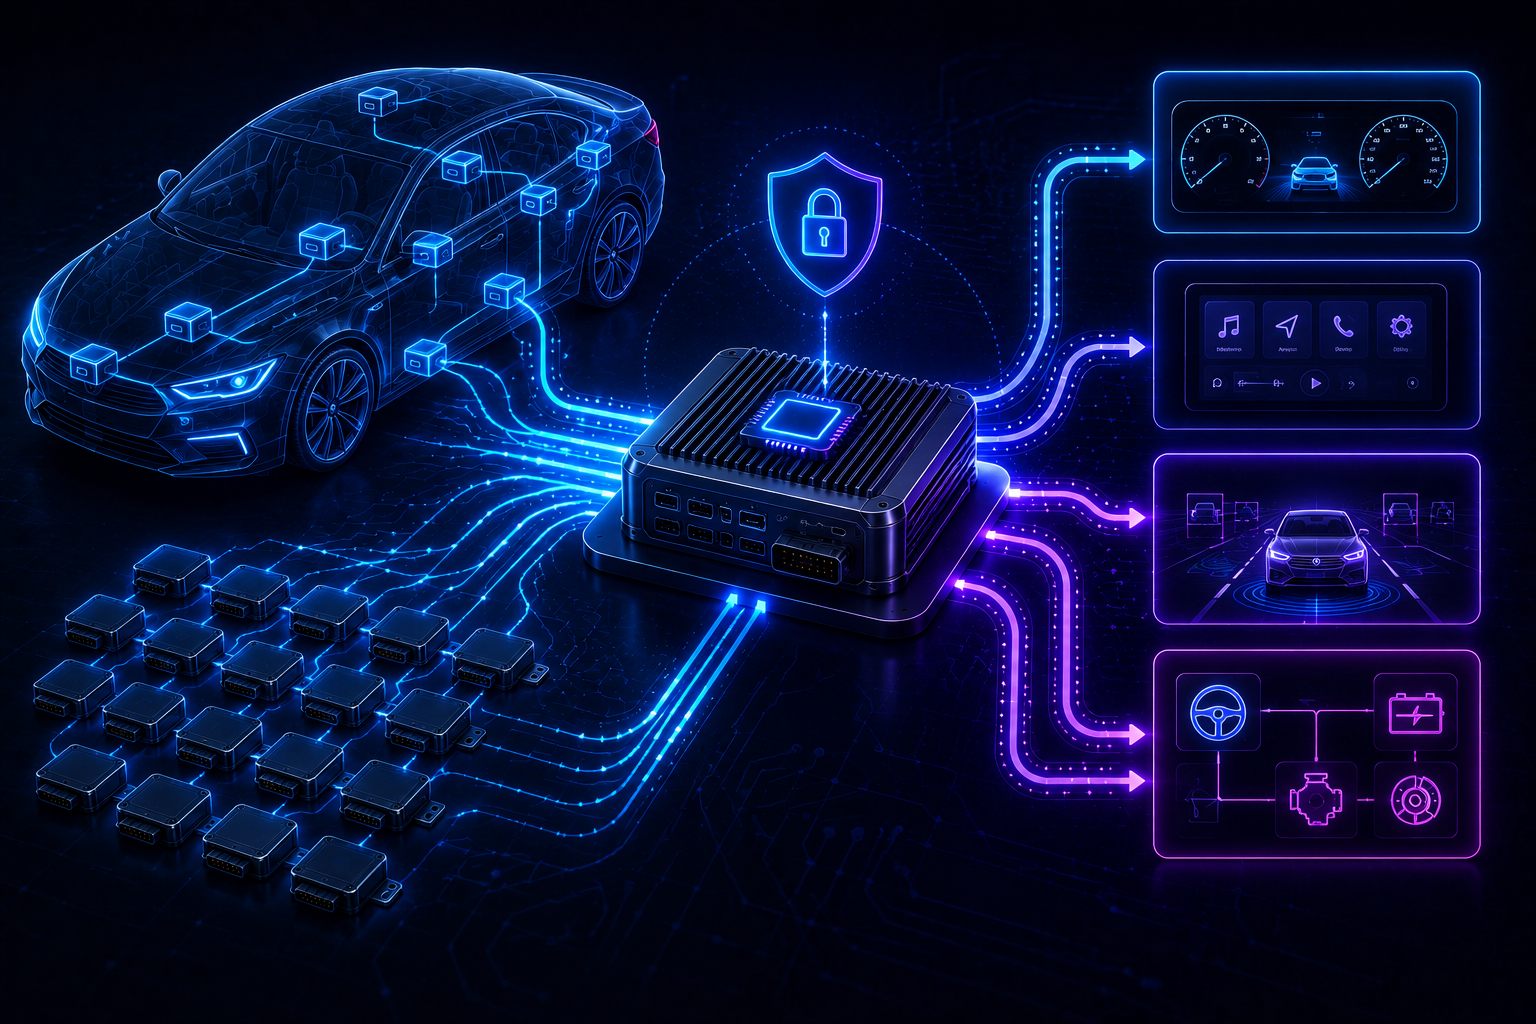
DriveOS proposes a centralized vehicle management architecture designed to replace the growing number of dedicated ECUs with software-defined functions running on a single multicore computing platform. Built around a separation kernel, DriveOS securely partitions critical real-time services from non-critical Linux or Android workloads while enabling controlled communication between them.
The platform integrates instrument cluster, infotainment and ADAS services with real-time vehicle control and CAN bus processing. Using secure shared memory and predictable real-time I/O, DriveOS enables applications of different criticality levels to coexist while maintaining timing guarantees, hardware isolation and controlled access to vehicle sensors and actuators. The system was evaluated through hardware-in-the-loop CARLA simulation using real vehicle data.
Enter your details below to access the full research paper.