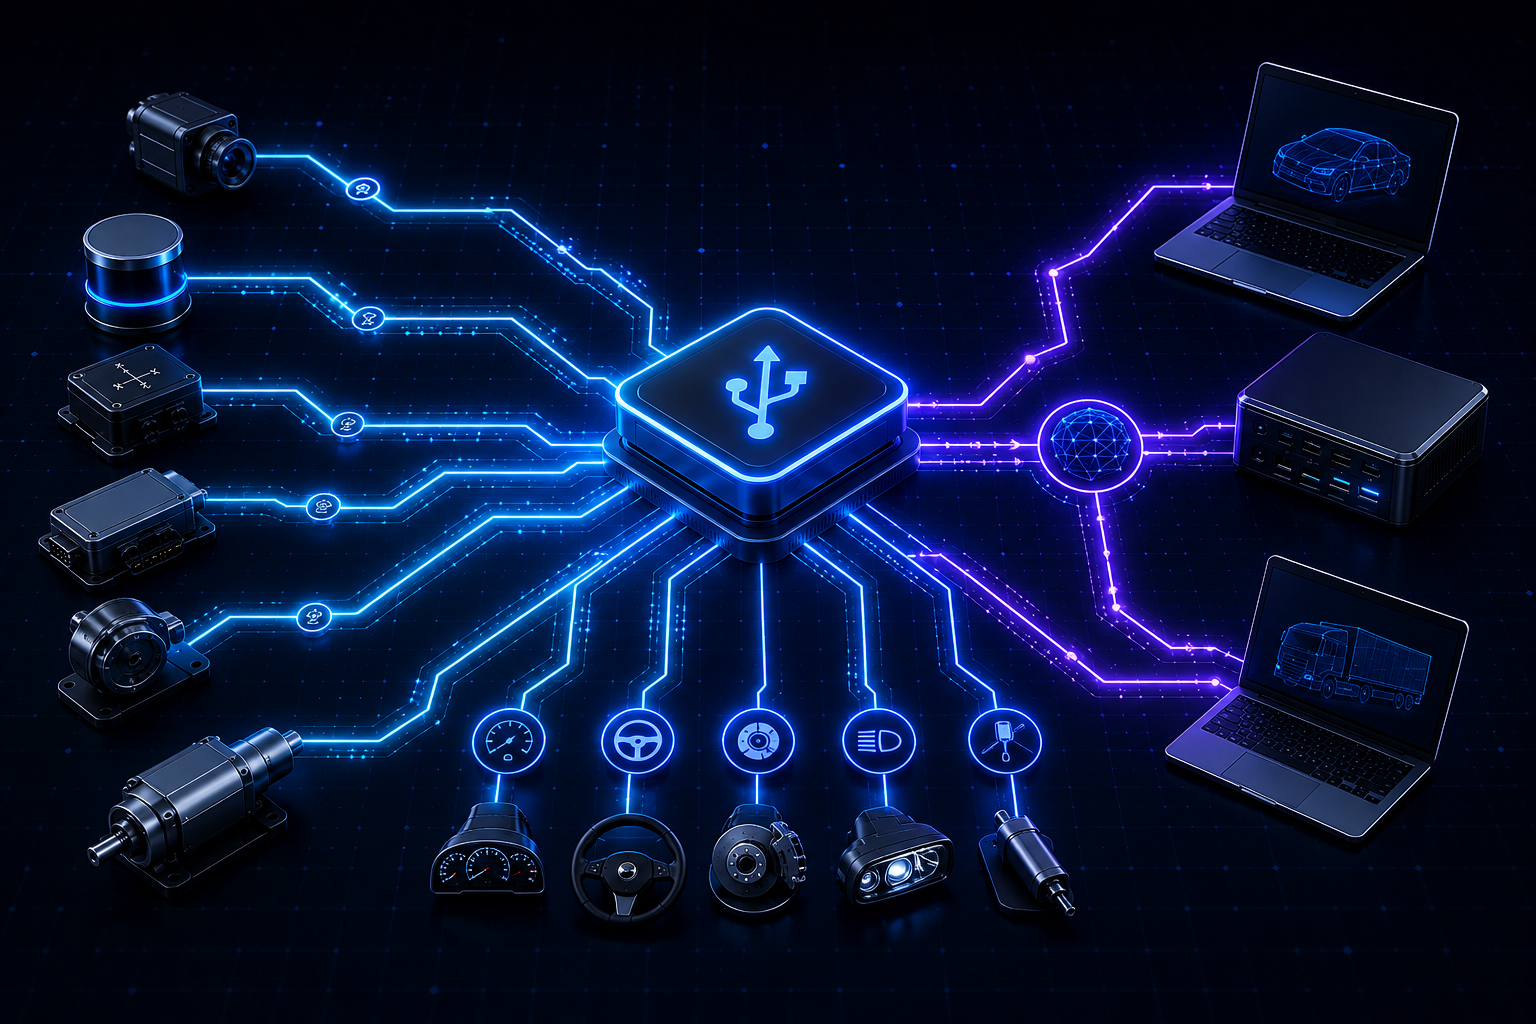
This research explores how USB can provide both real-time device I/O and host-to-host communication in multicore embedded systems. The proposed approach combines real-time USB 3.x bus scheduling, coordinated task and interrupt scheduling, and a time-aware “Tuned Pipes” abstraction to support end-to-end latency and throughput guarantees. The system enables sensors, actuators, and multiple host computers to share a unified USB-based communication architecture, offering a potential high-bandwidth alternative to traditional embedded buses such as CAN.
Enter your details below to access the full research paper.