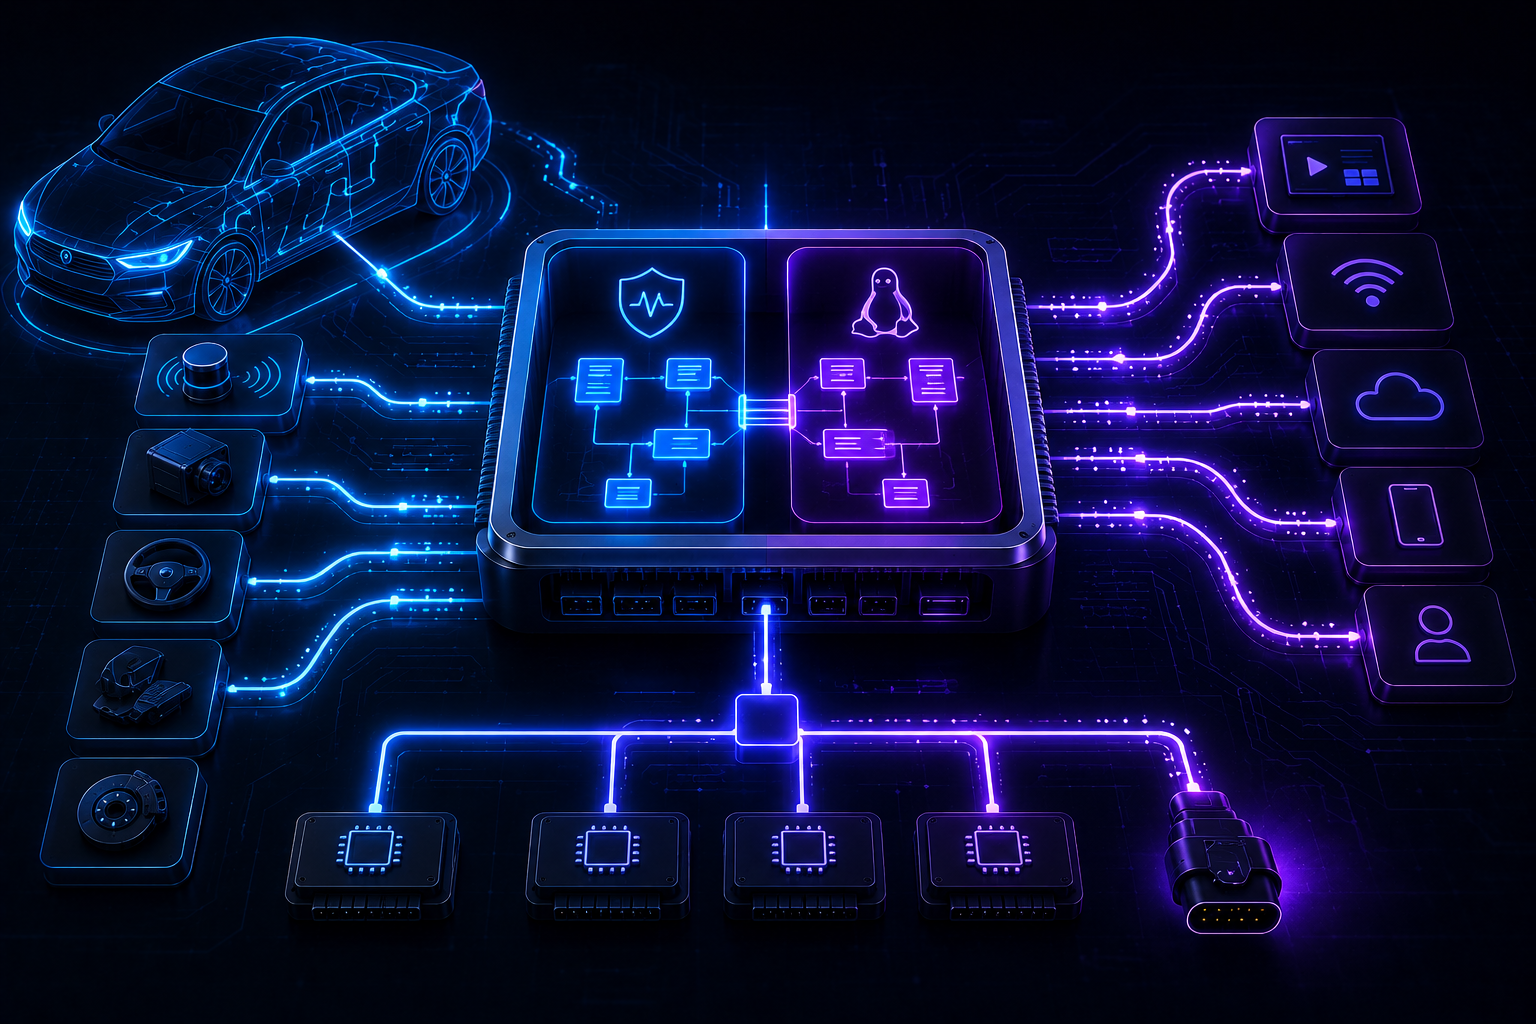
ModelMap is a model-based application development framework designed for DriveOS, a centralized vehicle management system running isolated real-time and Linux domains on multicore hardware. It extends Simulink-based vehicle development across multiple operating-system domains, automatically generating periodic tasks, supporting synchronous and asynchronous cross-domain communication, and providing real-time USB-CAN I/O. ModelMap also introduces nested binaries for deploying executable code across different sandboxed domains. The framework is demonstrated through synthetic benchmarks and real automotive CAN Gateway and HVAC applications, showing predictable end-to-end performance on a centralized vehicle computing platform.
Enter your details below to access the full research paper.